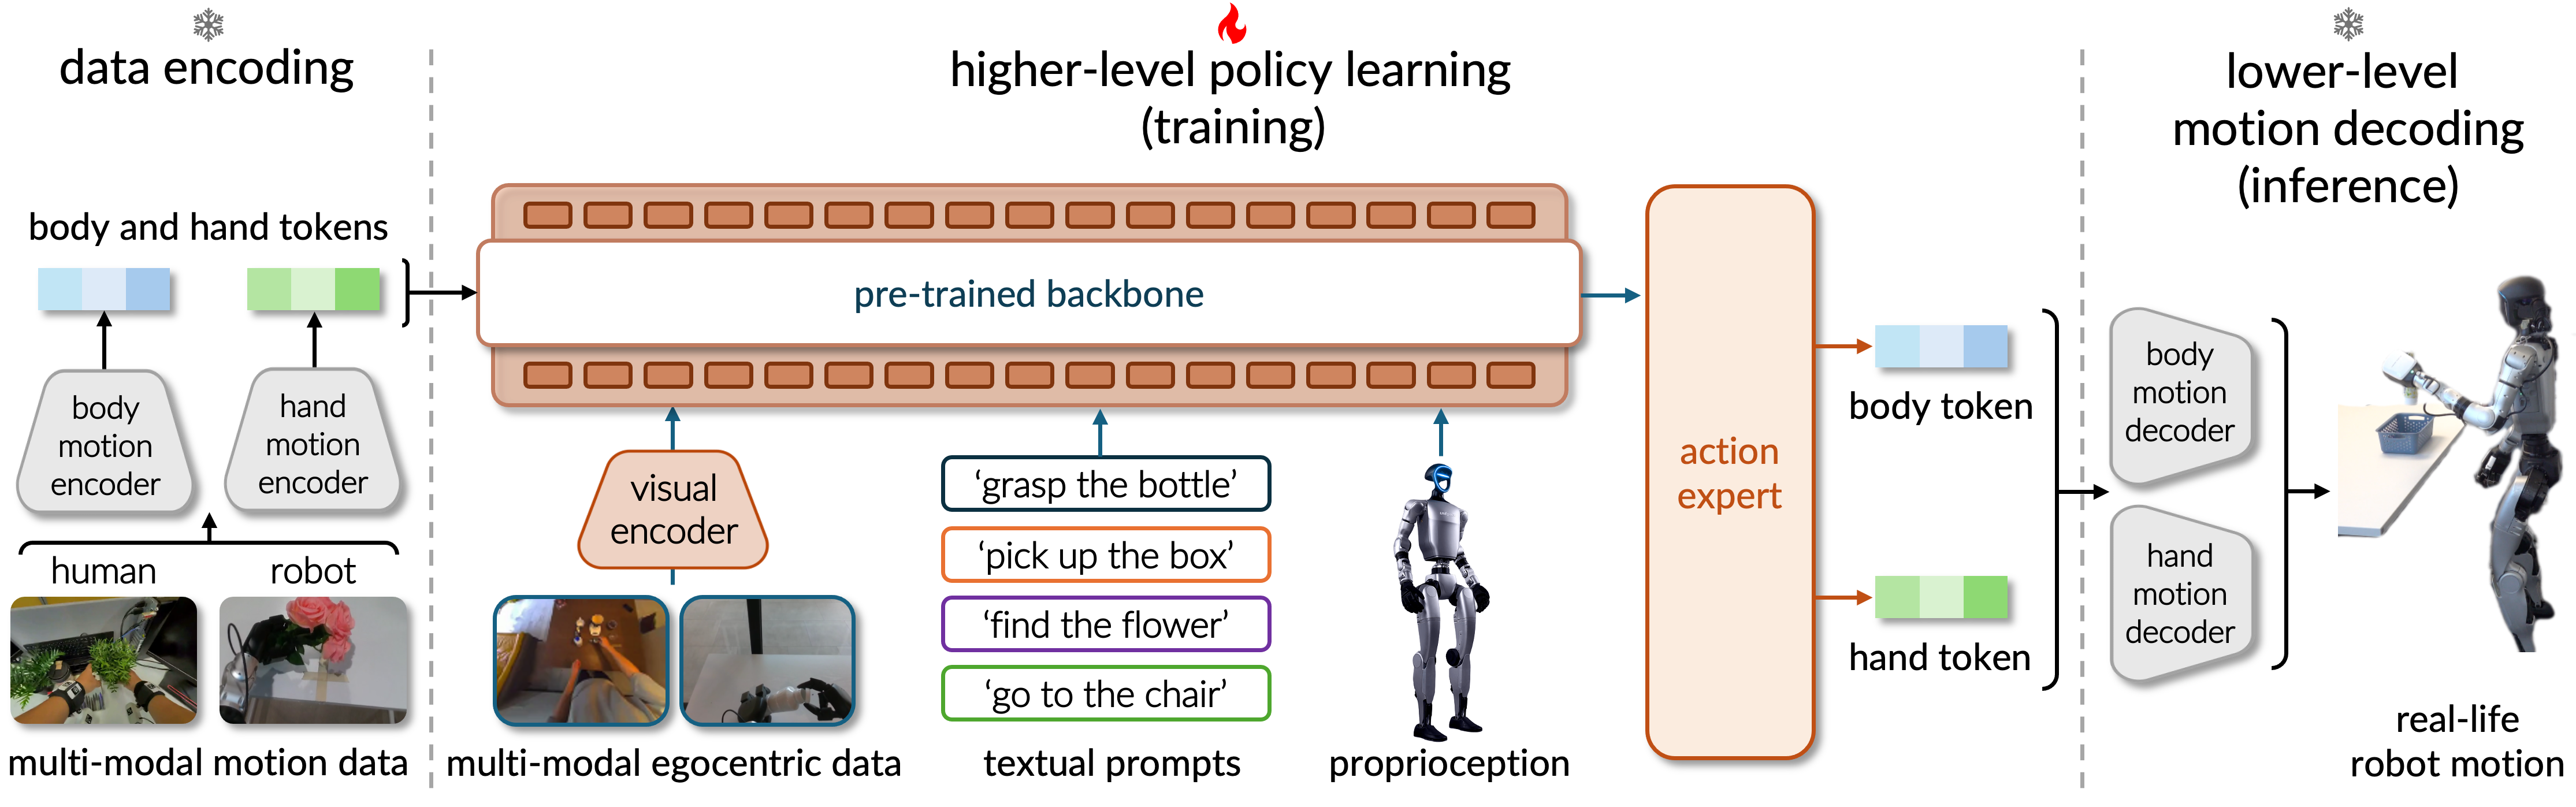
VioLA: Learning Generalist Humanoid Control Policies from Human Data
* Equal contribution.
arXiv · 2026
A generalist humanoid policy learned mostly from human data, enabling zero-shot locomotion and manipulation.
PhD Student in Robotics and Reinforcement Learning
I am a PhD student at ETH Zürich and the Max Planck Institute for Intelligent Systems, co-advised by Michael J. Black and Andreas Krause. I am also an ELLIS PhD student and a CLS Fellow.
I am currently interning at Meta in London, Reality Labs, working on world action models (WAMs) and
self-supervised learning.
Previously, I interned at Vesoma with Martin Riedmiller, developing generalist humanoid control policies, and at Meshcapade, working on text-to-motion synthesis for humanoid robots.
My research focuses on robot learning and reinforcement learning at scale, particularly learning from human data and self-improvement. I am interested in using human motion, video, demonstrations, and synthetic data to give robots a broad foundation of skills, then enabling them to refine and extend those skills through their own experience. The aim is generalist policies that keep improving and adapt to new tasks and environments.
* Equal contribution.
arXiv · 2026
A generalist humanoid policy learned mostly from human data, enabling zero-shot locomotion and manipulation.
Ongoing work · Paper in preparation
Developed during my internship at Vesoma with Martin Riedmiller.
CVPR 2026
Spotlight talk · 2nd Workshop on Agents in Interaction, from Humans to Robots.
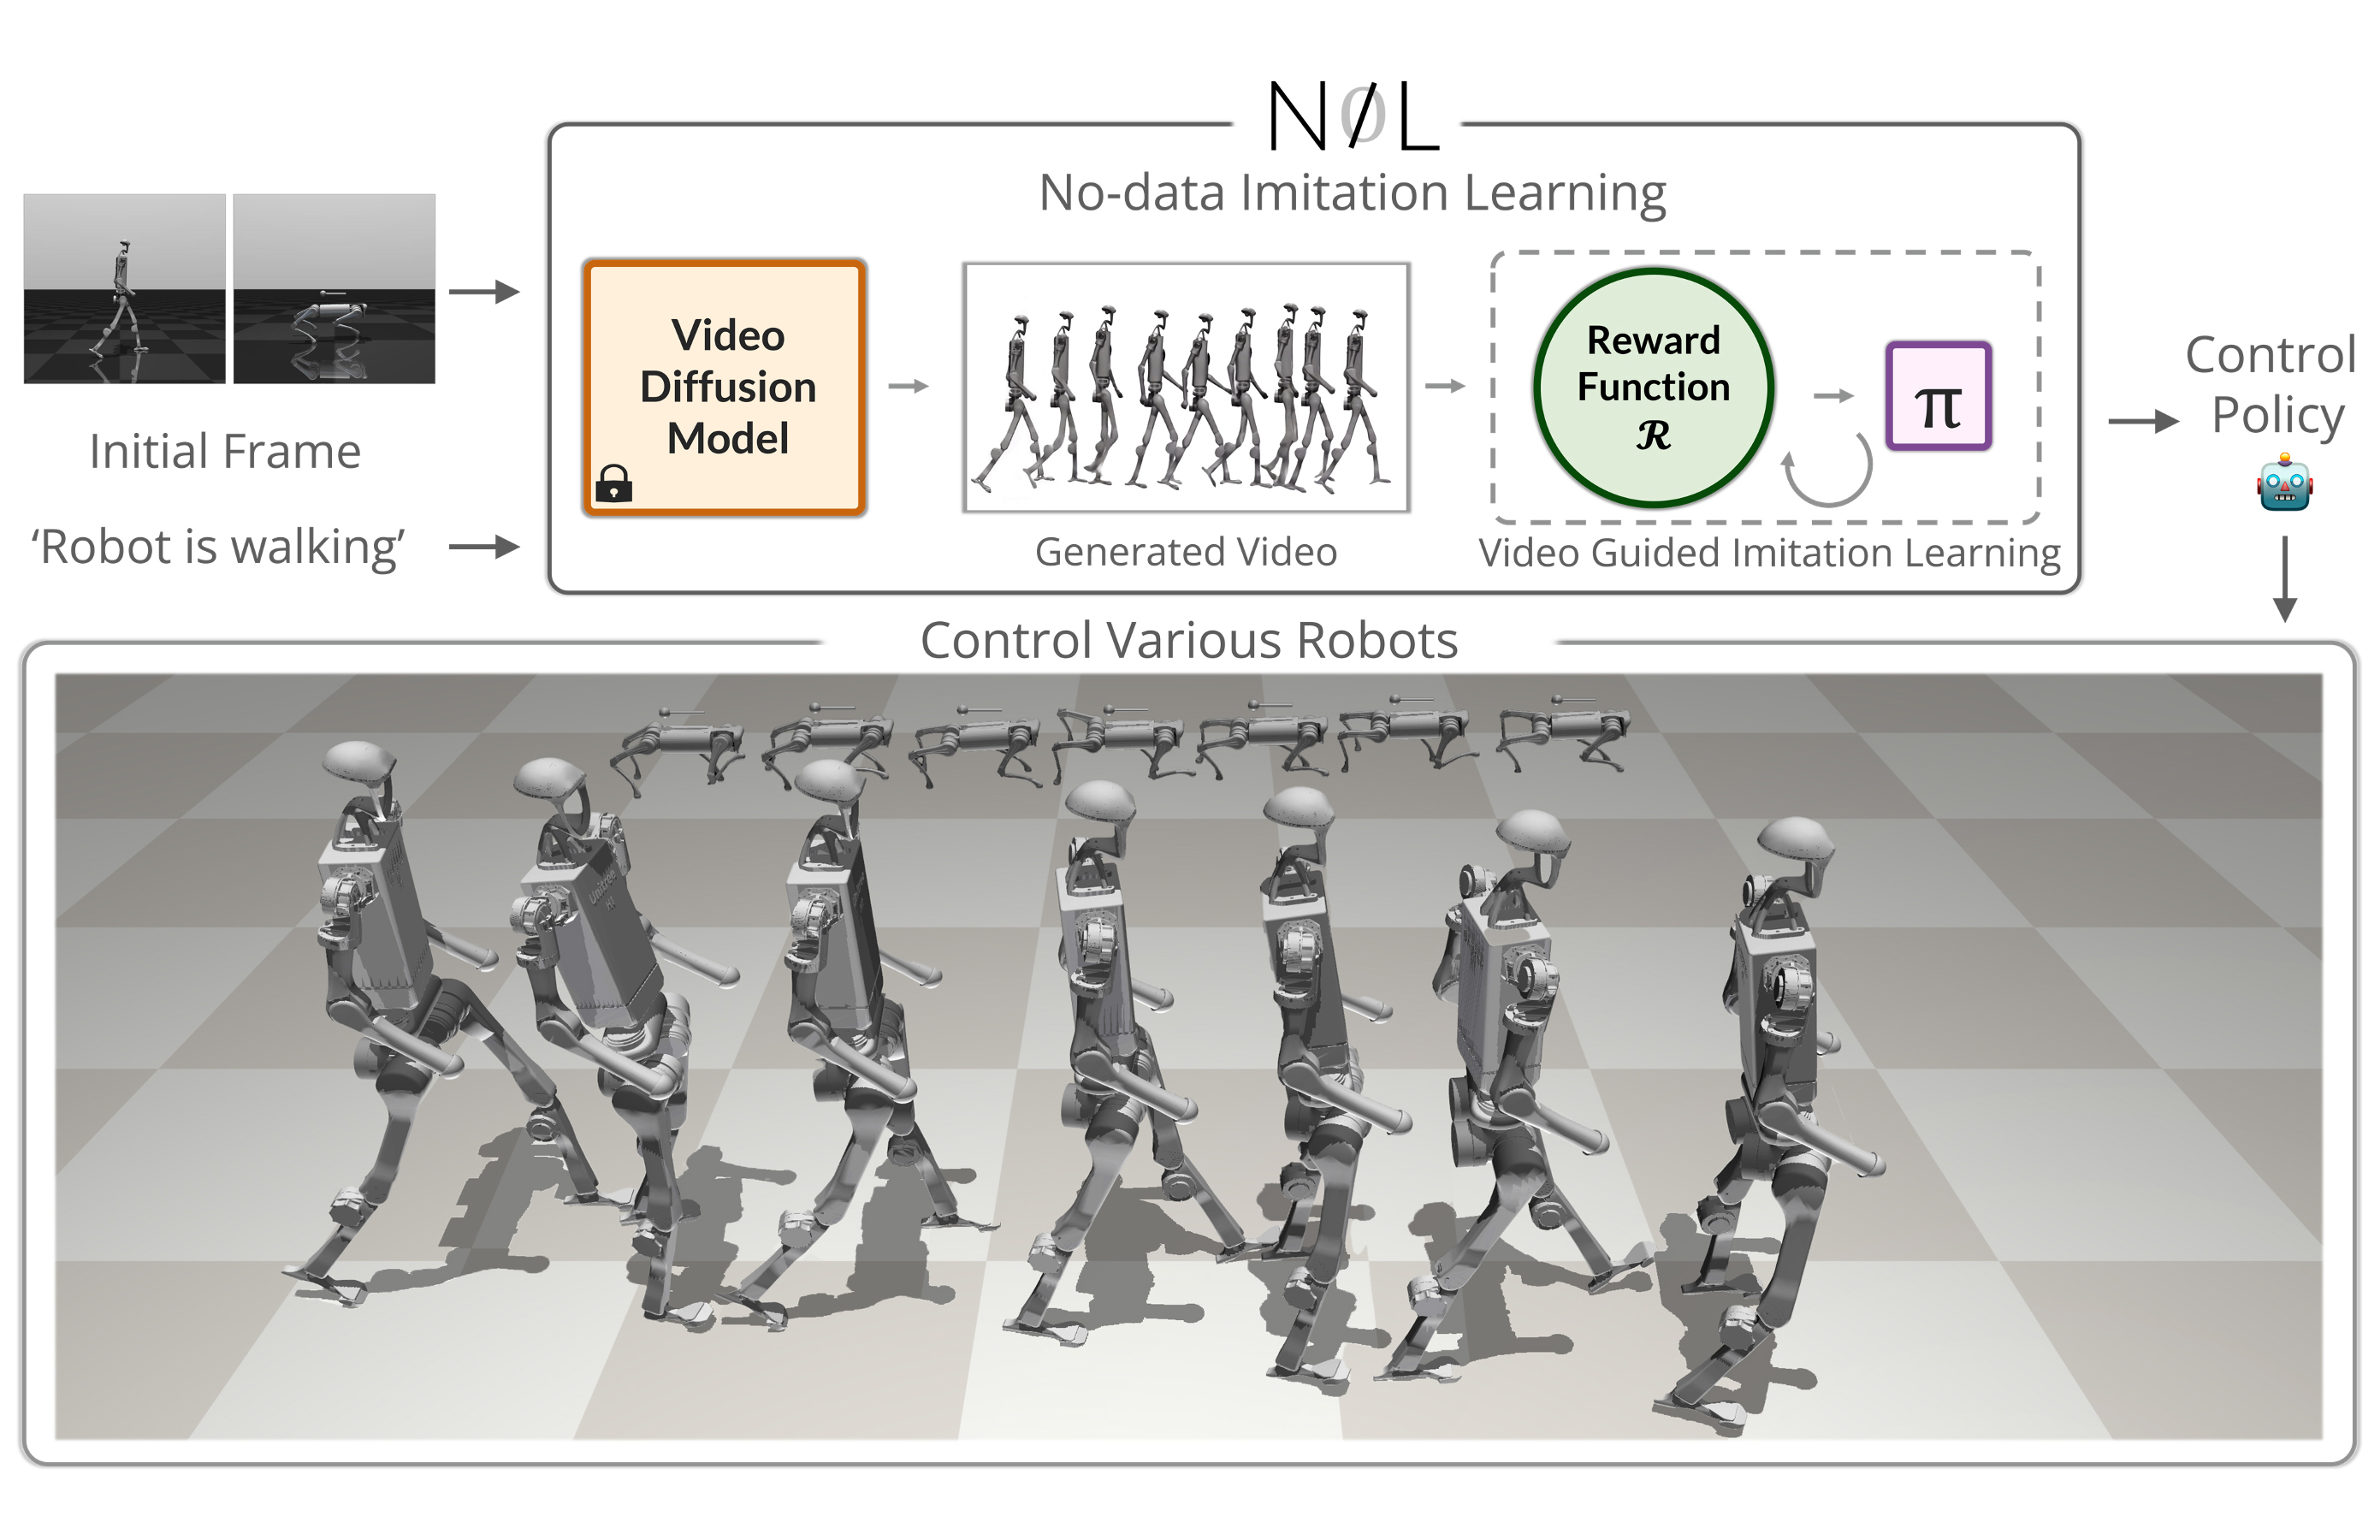
Learning robot skills from generated videos, without curated expert demonstrations.

* Equal contribution.
ICML 2026 · PMLR 306:5200–5218
Adapting goal-conditioned policies at test time using relevant experience from an offline dataset.

arXiv preprint arXiv:2509.19259 · 2025
Controlling avatar motion from egocentric vision by combining a learned motion prior with reinforcement learning.
arXiv preprint arXiv:2406.08472 · 2025
Poster at the 7th Robot Learning Workshop: Towards Robots with Human-Level Abilities, ICLR 2025 (non-archival)
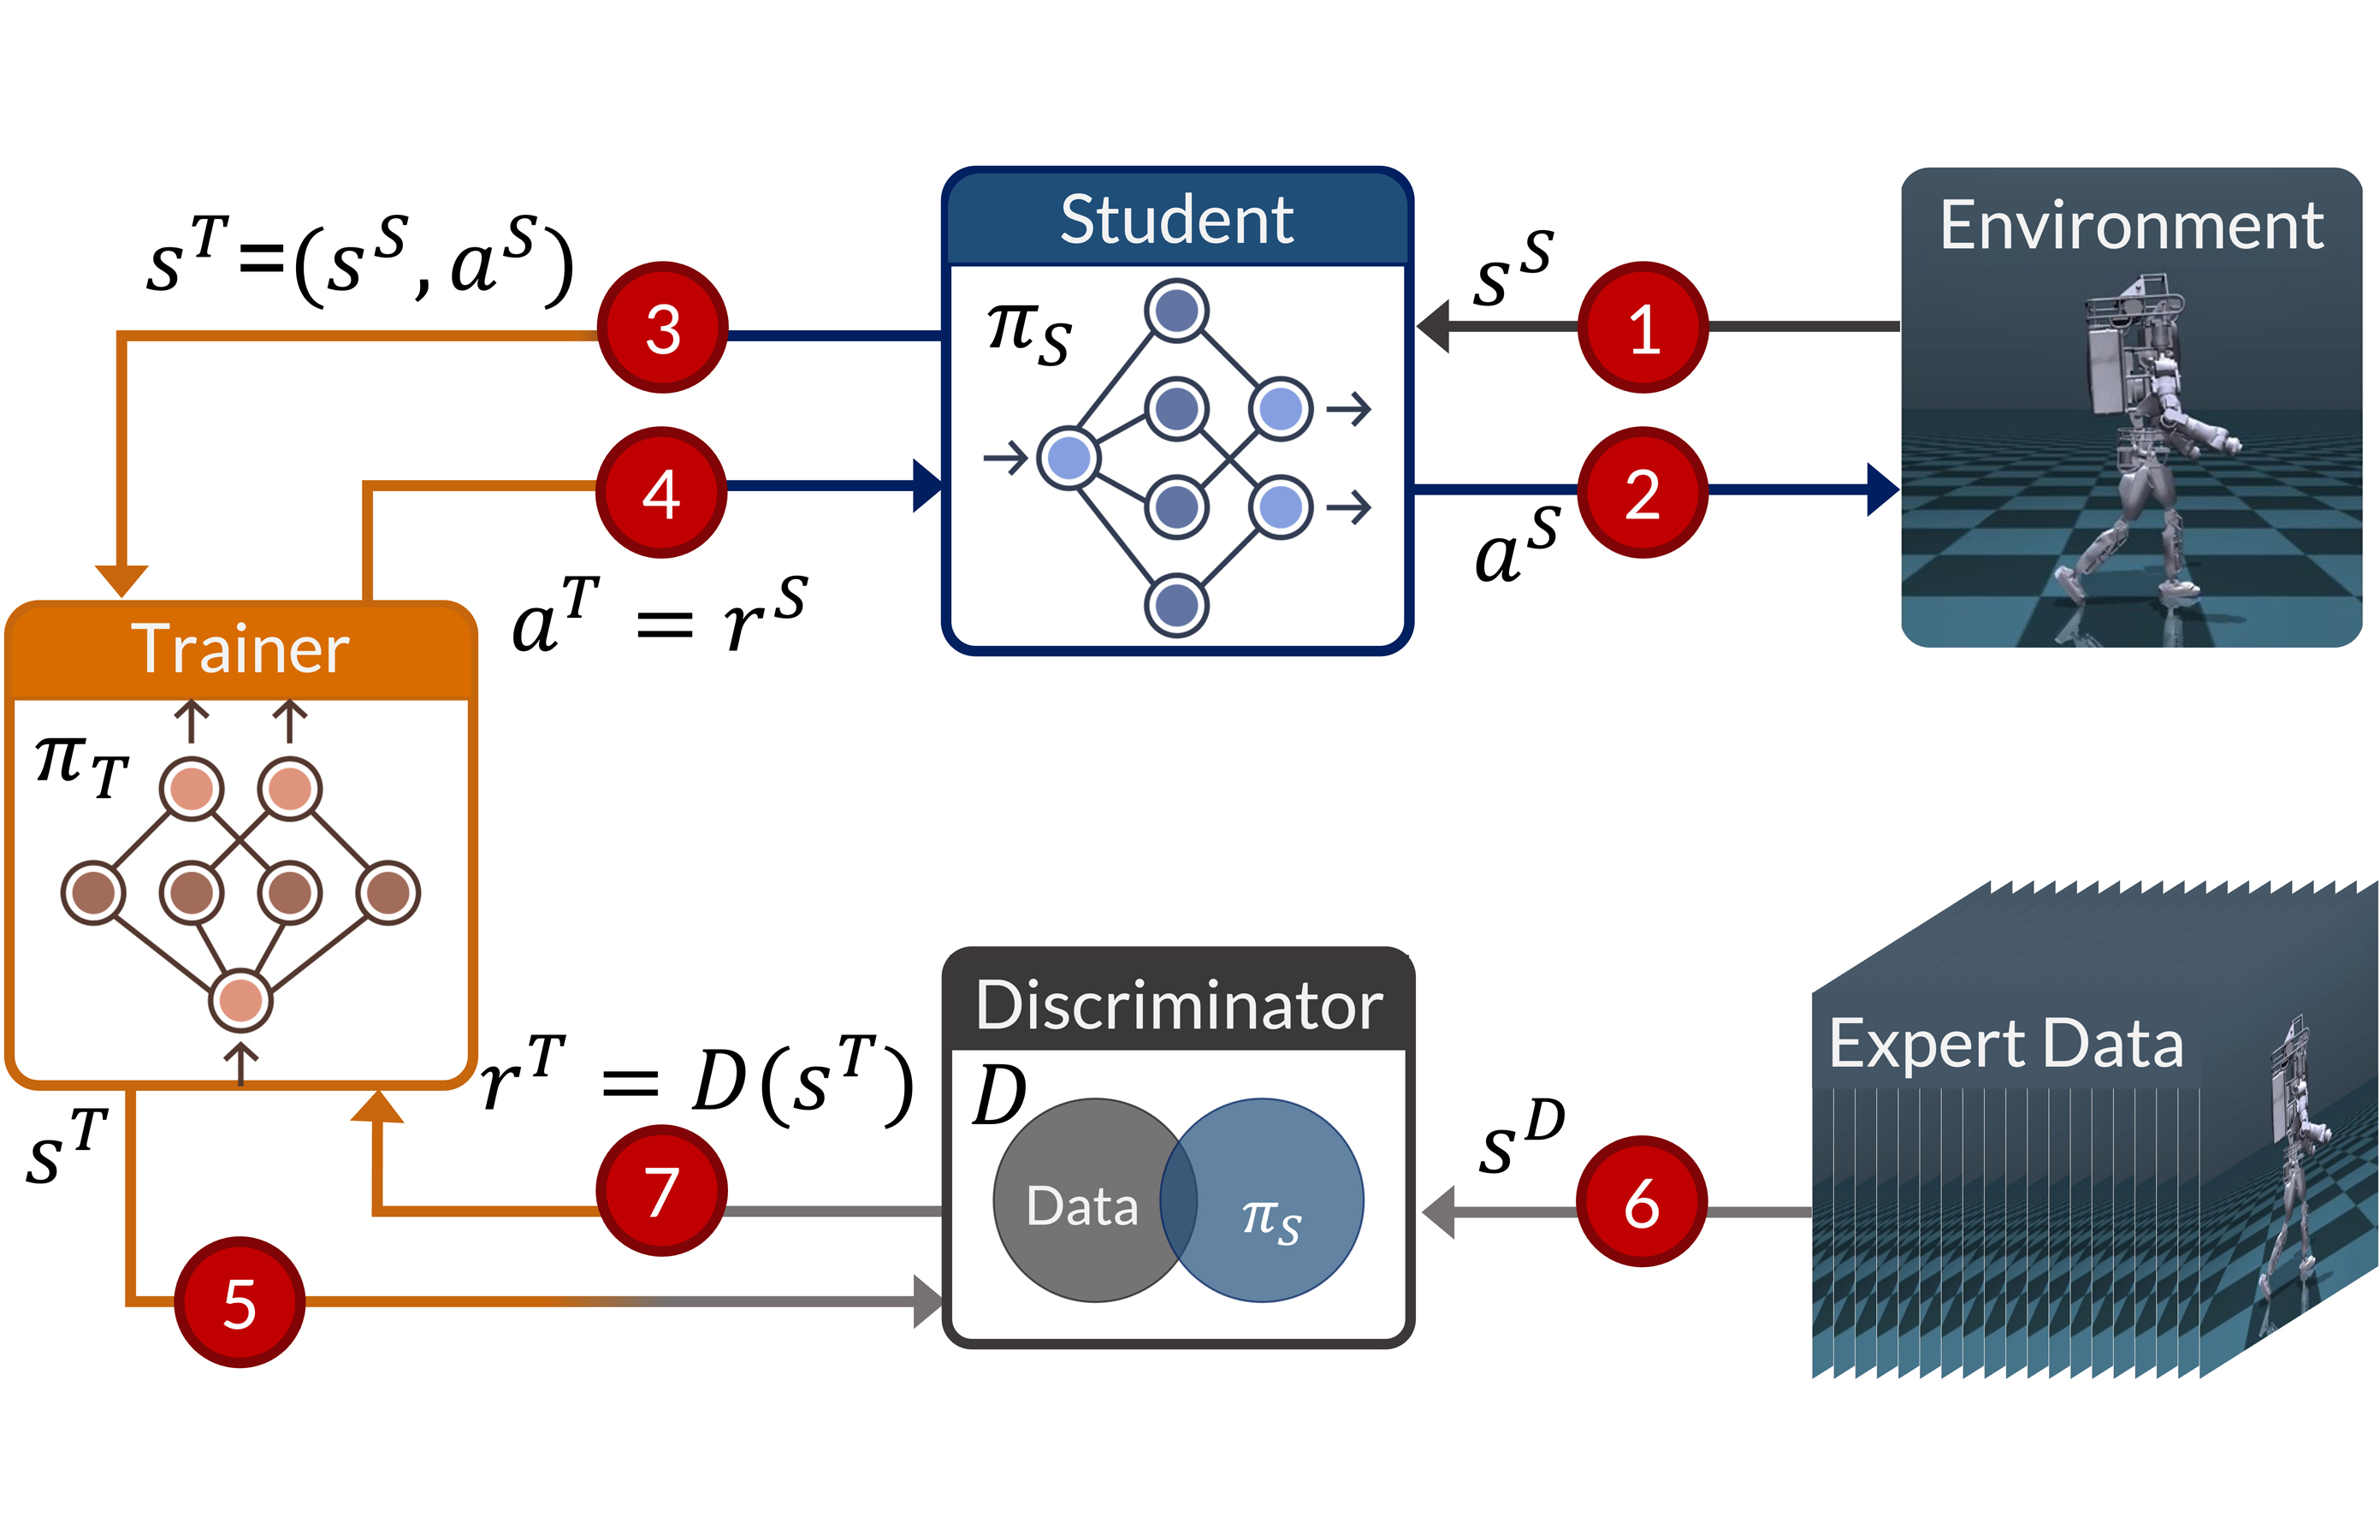
Learning a reward function and an imitation policy together, with an RL-based trainer guiding a student toward expert behavior.

Proceedings of the ACM on Human-Computer Interaction · 2024

Proceedings of the 2024 Symposium on Eye Tracking Research and Applications · 2024

Transportation Research Part C: Emerging Technologies · 2021

IEEE Transactions on Control Systems Technology · 2021

2020 25th International conference on pattern recognition (ICPR) · 2021

2019 American Control Conference (ACC) · 2019

Annual Reviews in Control · 2019
Research Intern
World action models (WAMs) and self-supervised learning.
Research Intern
Generalist humanoid control policies, vision-language-action models (VLAs), and world action models (WAMs).
Machine Learning Research Intern
Text-to-motion synthesis for humanoid robots.
PhD Student
Humanoid robots, robot learning, and reinforcement learning.
Outside research, I enjoy photography and drawing. A selection of my work →