Research
Selected projects in robotics and reinforcement learning.
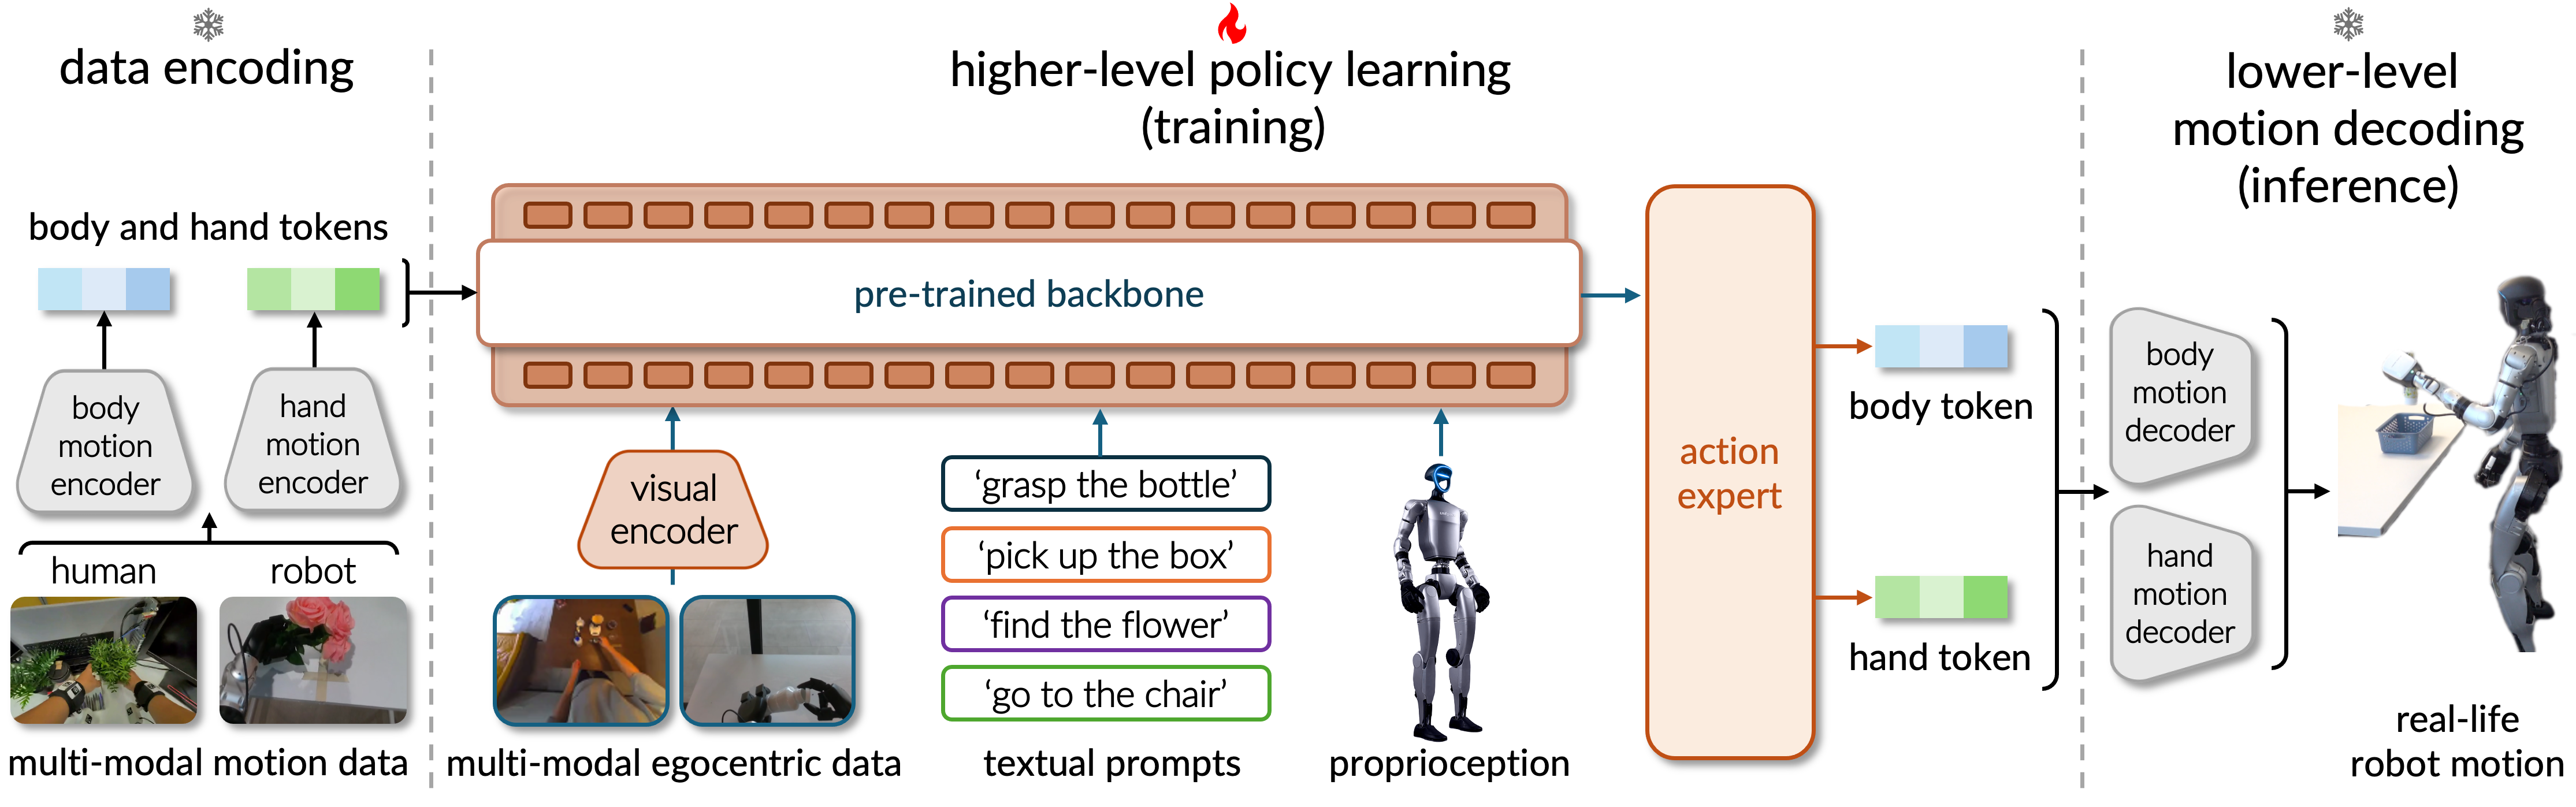
VioLA: Learning Generalist Humanoid Control Policies from Human Data
arXiv, 2026 · * Equal contribution
A generalist humanoid policy learned mostly from human data, enabling zero-shot locomotion and manipulation.
Dr. Octopus: Universal Hand Controller
Ongoing work · Paper in preparation
Developed during my internship at Vesoma with Martin Riedmiller.

NIL: No-data Imitation Learning
CVPR 2026
Learning robot skills from generated videos, without curated expert demonstrations.
Also presented as a spotlight talk at the 2nd Workshop on Agents in Interaction, from Humans to Robots.

GC-TTT: Test-time Offline Reinforcement Learning on Goal-related Experience
ICML 2026 · * Equal contribution
Adapting goal-conditioned policies at test time by selecting relevant experience from an offline dataset and applying a few steps of policy improvement.
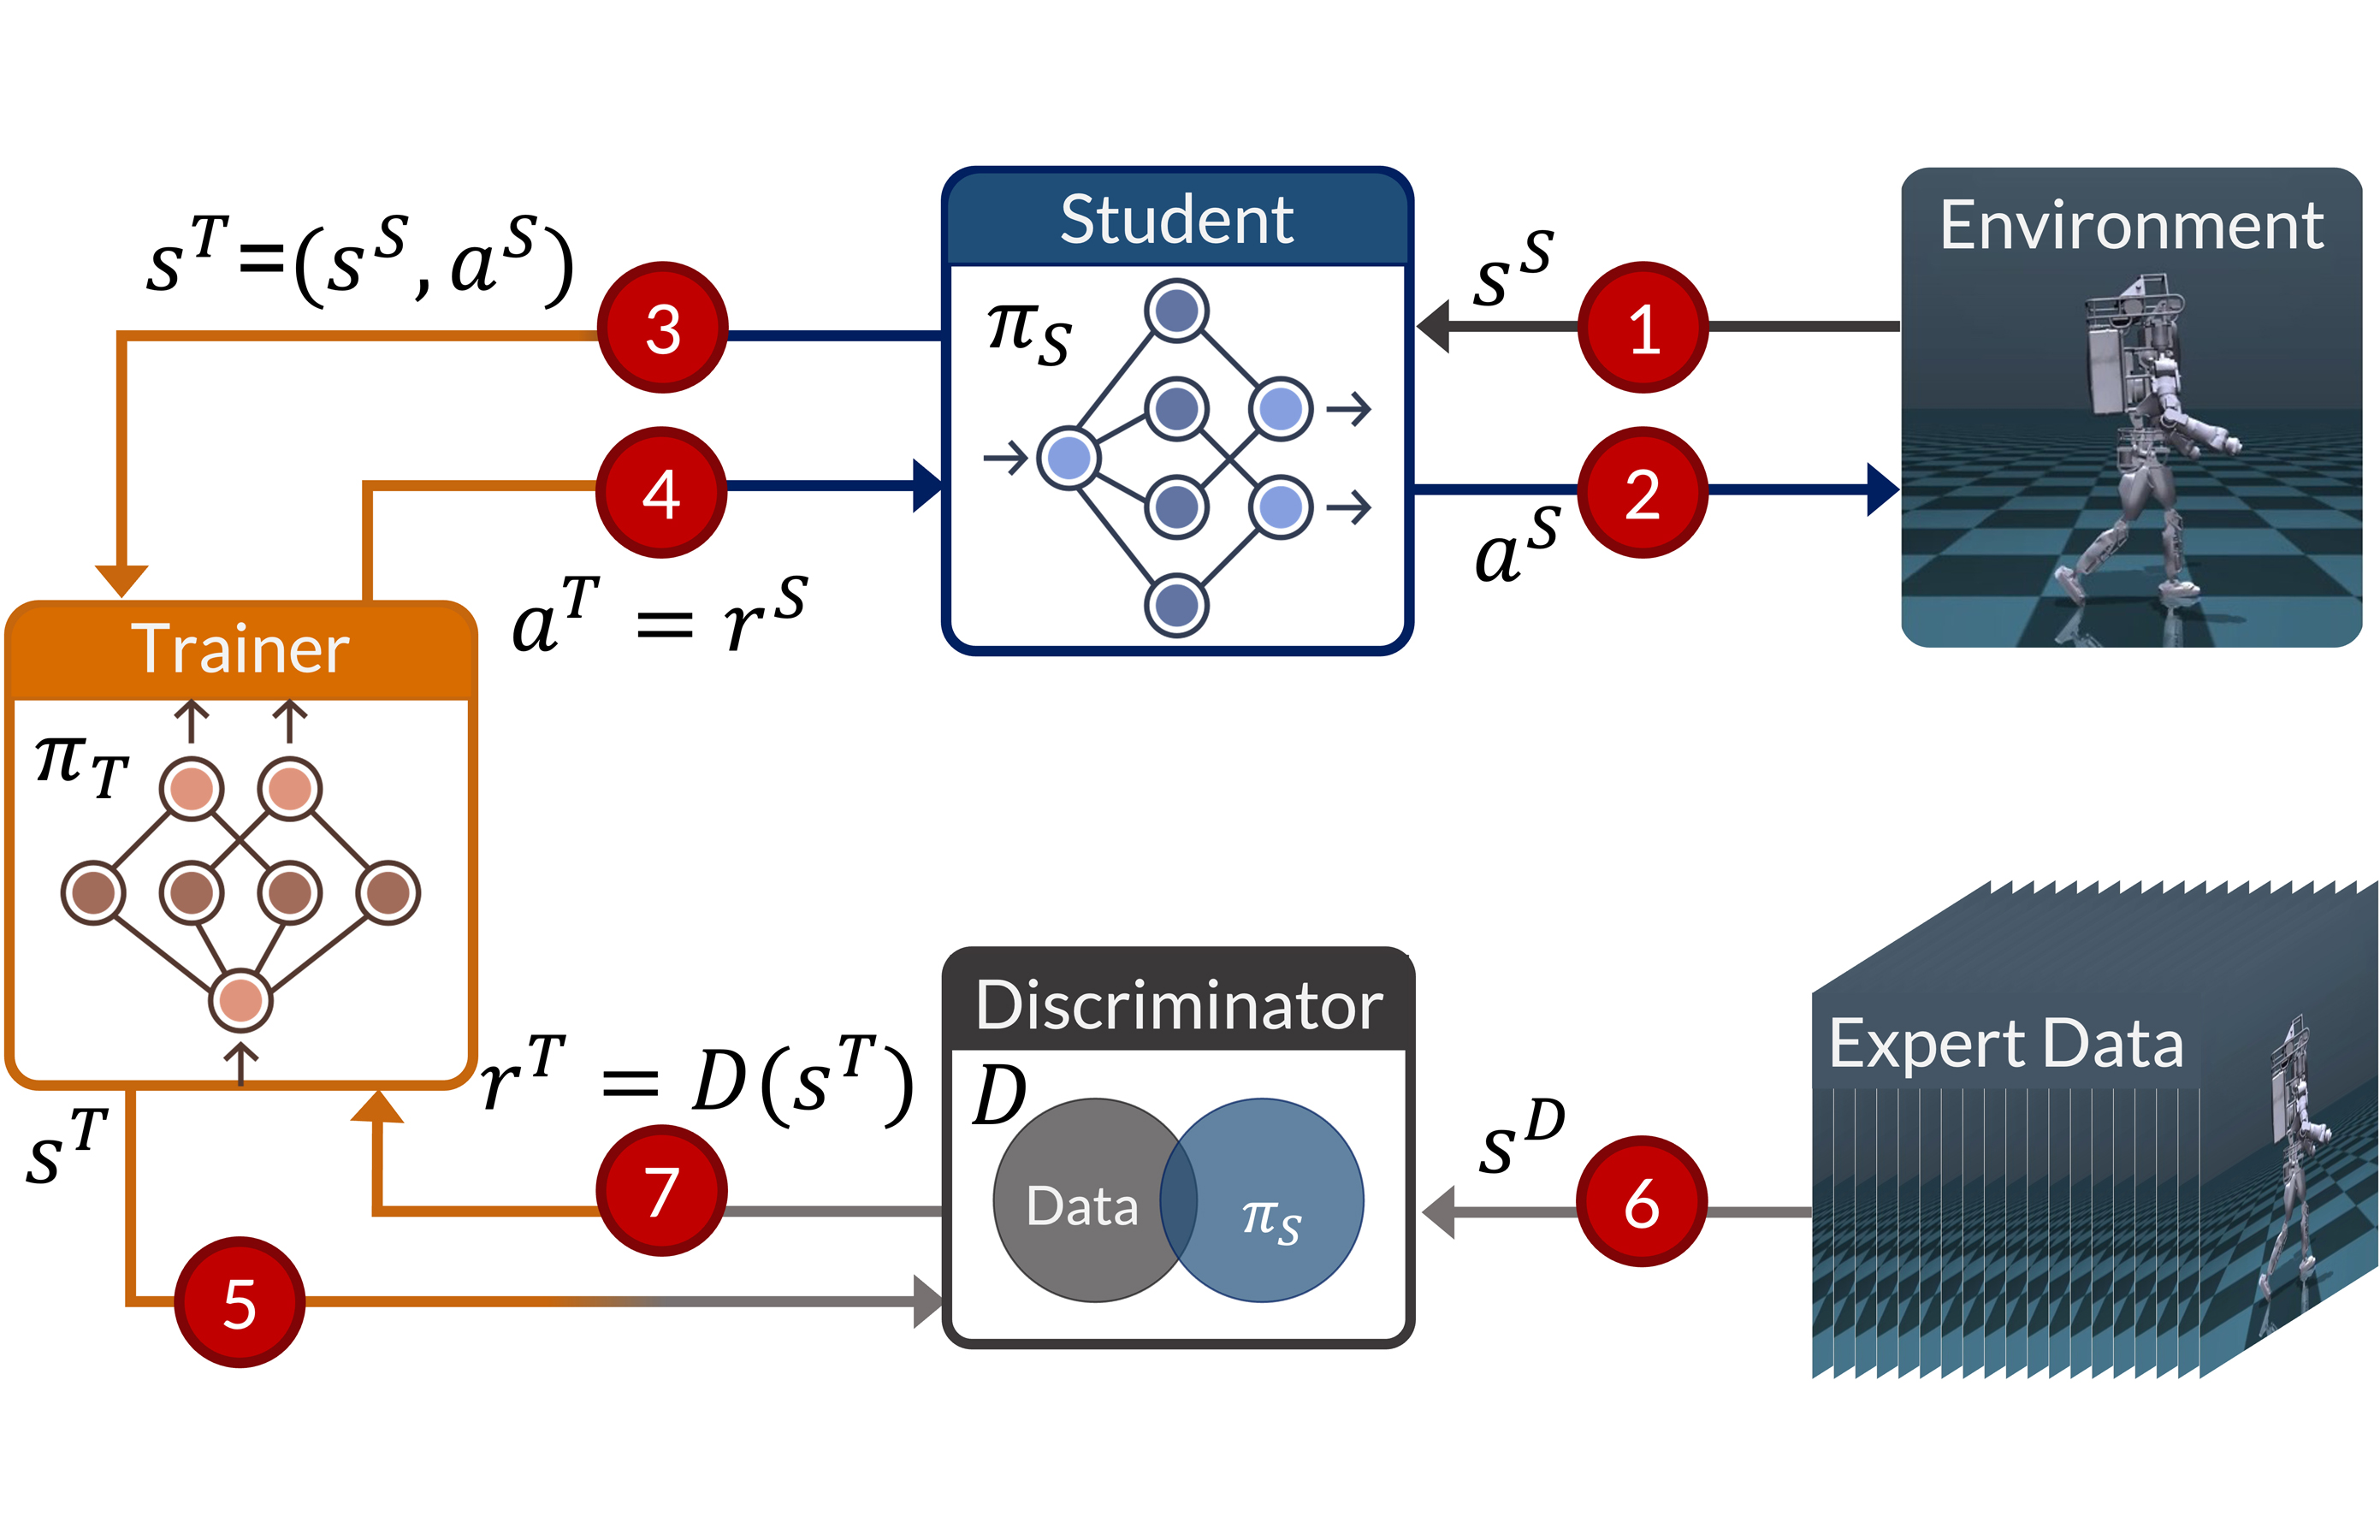
RILe: Reinforced Imitation Learning
ICLR 2025 Robot Learning Workshop · Poster (non-archival)
Learning a reward function and an imitation policy together: an RL-based trainer generates adaptive rewards that guide a student toward expert behavior.